MIT Researchers Develop a System That Helps Robots Recognise and Correct Their Own Mistakes
Industrial robots increasingly operate in environments where they must identify objects, remember their locations and perform tasks involving multiple steps.
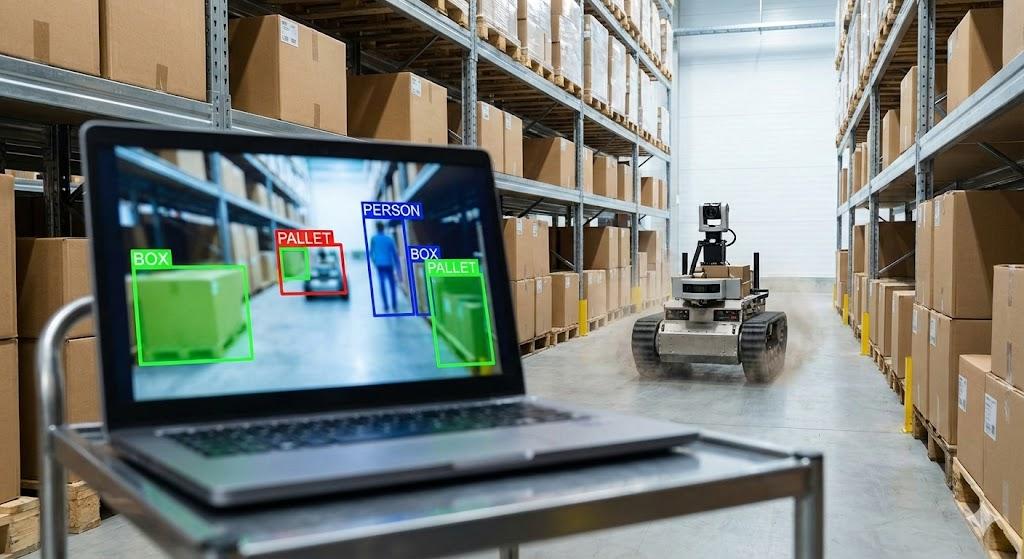
Industrial robots increasingly operate in environments where they must identify objects, remember their locations and perform tasks involving multiple steps.
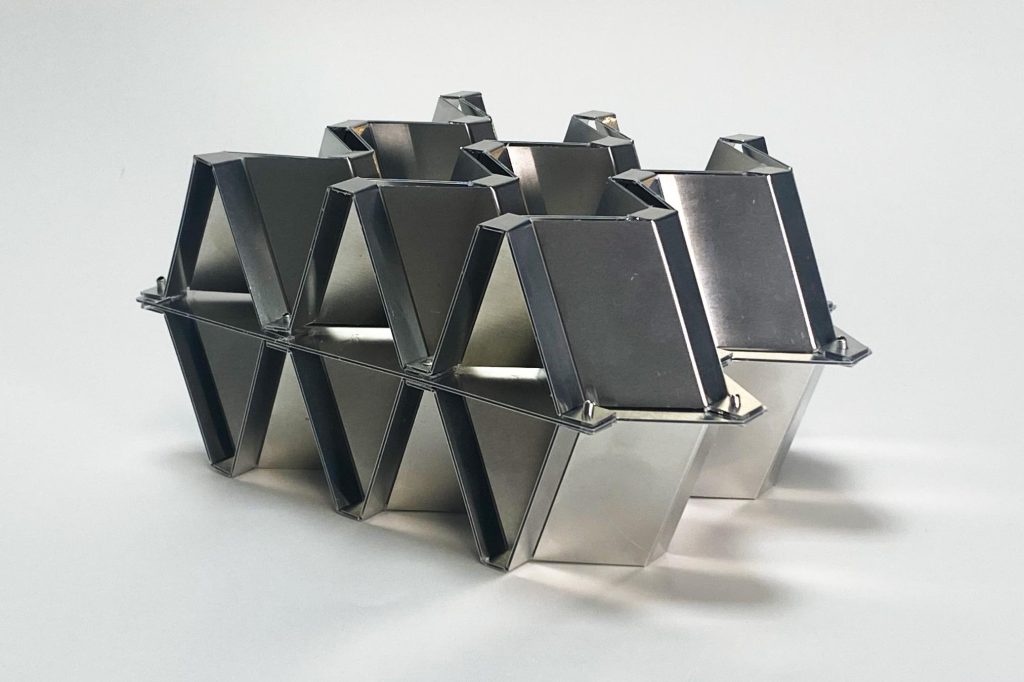
Reducing structural weight without sacrificing stiffness and load-bearing capacity is a central challenge in mechanical, aerospace and architectural engineering.